MetaPusher: Meta Learning and Planning for Nonprehensile Manipulation of Unseen Objects with Rapid Online Adaption
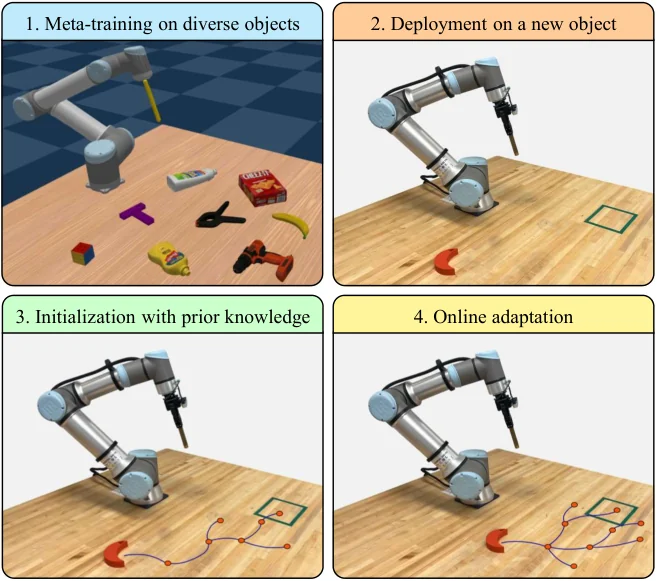
Manipulating previously unseen objects is difficult because friction and mass distribution are hidden and cannot be recovered reliably from vision; models transferred across objects can therefore start with substantial error. MetaPusher uses cross-object meta-learning to initialize object dynamics, then updates that model from interaction while a push is underway. Its adaptive kinodynamic planner reuses and refines the search tree as dynamics change, allowing planning and learning to proceed together without a separate data-collection stage. Simulated and sim-to-real experiments on unseen objects compare the method with fine-tuning, active learning, MPPI, and reinforcement learning; the reported results show lower prediction error and up to 20% higher task success.
BibTeX
@article{lee2026metapusher,
  title={MetaPusher: Meta Learning and Planning for Nonprehensile Manipulation of Unseen Objects with Rapid Online Adaption},
  author={Lee, Donghyung and Golestaneh, Seyedali and Singh, Jaskrit and Zhong, Zhuoyun and Kapoutsis, Athanasios and Chamzas, Constantinos},
  journal={arXiv preprint arXiv:2609.21122},
  year={2026}
}