Publications

Publications

Papers and preprints in robotics planning, learning, manipulation, and legged systems. Ali’s name is highlighted in each author list.

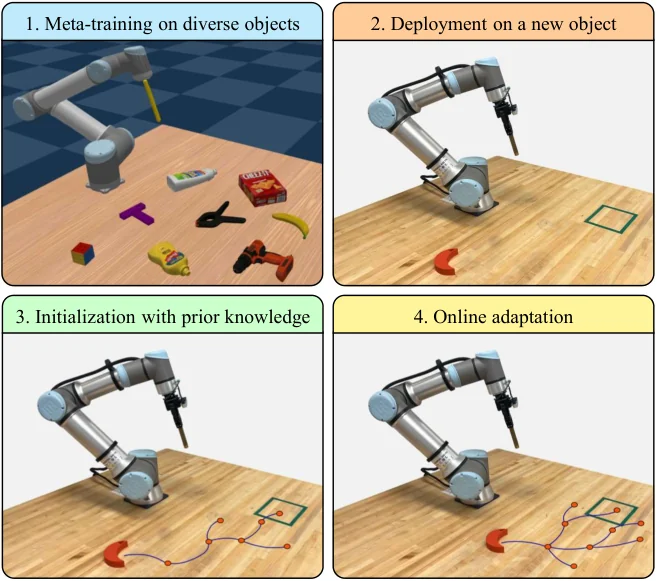
MetaPusher method overview showing meta-training, deployment on a new object, prior knowledge, and online adaptation
arXiv preprint2026Preprint

MetaPusher: Meta Learning and Planning for Nonprehensile Manipulation of Unseen Objects with Rapid Online Adaption

Donghyung Lee, Seyedali Golestaneh, Jaskrit Singh, Zhuoyun Zhong, Athanasios Kapoutsis, Constantinos Chamzas

Manipulating previously unseen objects is difficult because friction and mass distribution are hidden and cannot be recovered reliably from vision; models transferred across objects can therefore start with substantial error. MetaPusher uses cross-object meta-learning to initialize object dynamics, then updates that model from interaction while a push is underway. Its adaptive kinodynamic planner reuses and refines the search tree as dynamics change, allowing planning and learning to proceed together without a separate data-collection stage. Simulated and sim-to-real experiments on unseen objects compare the method with fine-tuning, active learning, MPPI, and reinforcement learning; the reported results show lower prediction error and up to 20% higher task success.

arXiv
BibTeX
@article{lee2026metapusher,
  title={MetaPusher: Meta Learning and Planning for Nonprehensile Manipulation of Unseen Objects with Rapid Online Adaption},
  author={Lee, Donghyung and Golestaneh, Seyedali and Singh, Jaskrit and Zhong, Zhuoyun and Kapoutsis, Athanasios and Chamzas, Constantinos},
  journal={arXiv preprint arXiv:2609.21122},
  year={2026}
}
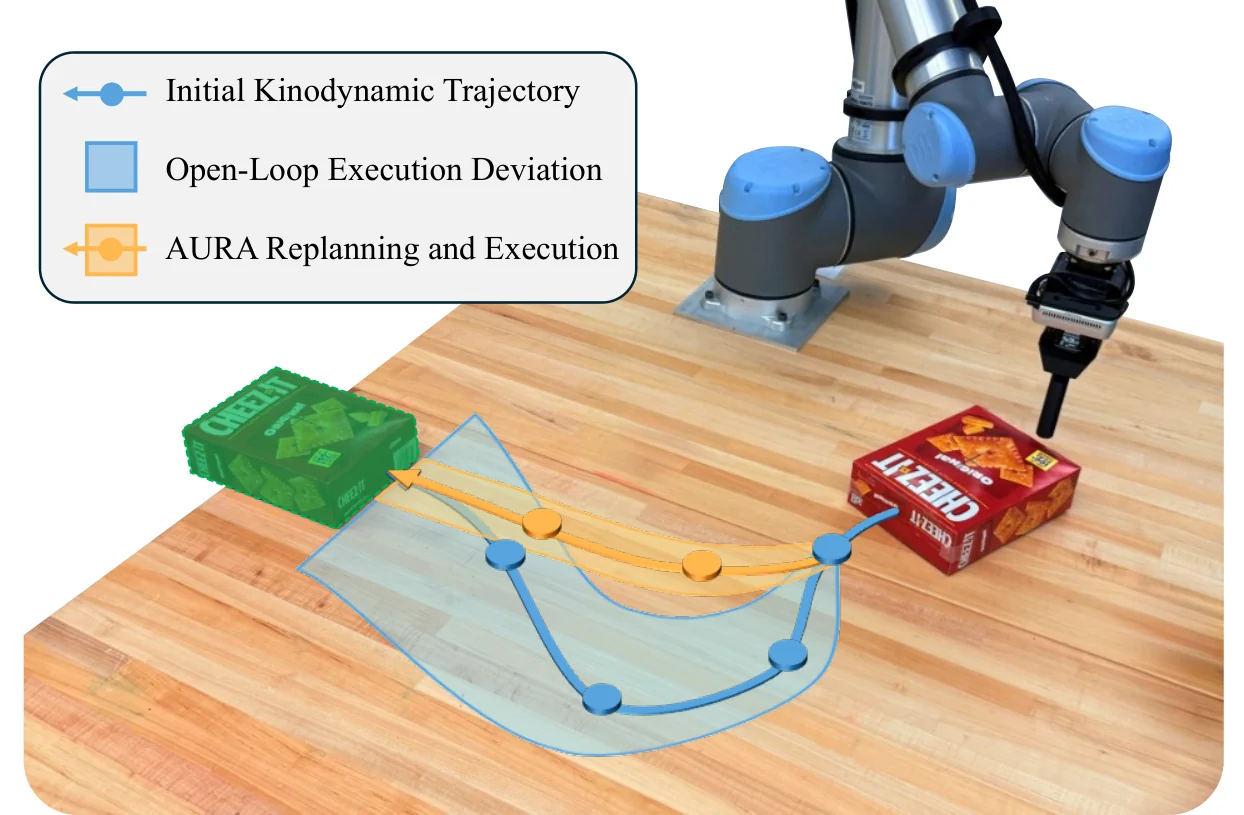
AURA illustration of a robot pushing an object, an execution deviation, and replanned paths
IEEE Robotics and Automation Letters2026Accepted · Sep 2026

AURA: Asymptotically Optimal Uncertainty-Robust Replanning Algorithm for Kinodynamic Systems

Seyedali Golestaneh, Zhuoyun Zhong, Donghyung Lee, Constantinos Chamzas

Sampling-based kinodynamic planners support high-dimensional, underactuated, and nonholonomic robots, but are generally used offline. During execution, motion uncertainty can drive a robot away from its planned trajectory. AURA is an asymptotically optimal meta-planner that continues exploring the state space and refining a trajectory online while optimizing future control inputs to reduce tracking error. This couples replanning with execution instead of waiting for a deviation before planning again. Simulated and real-world evaluations across multiple systems report improved trajectory quality, tracking accuracy, and overall performance compared with the evaluated baselines.

PaperarXivCode
BibTeX
@article{golestaneh2026aura,
  title={AURA: Asymptotically Optimal Uncertainty-Robust Replanning Algorithm for Kinodynamic Systems},
  author={Golestaneh, Seyedali and Zhong, Zhuoyun and Lee, Donghyung and Chamzas, Constantinos},
  journal={IEEE Robotics and Automation Letters},
  year={2026}
}
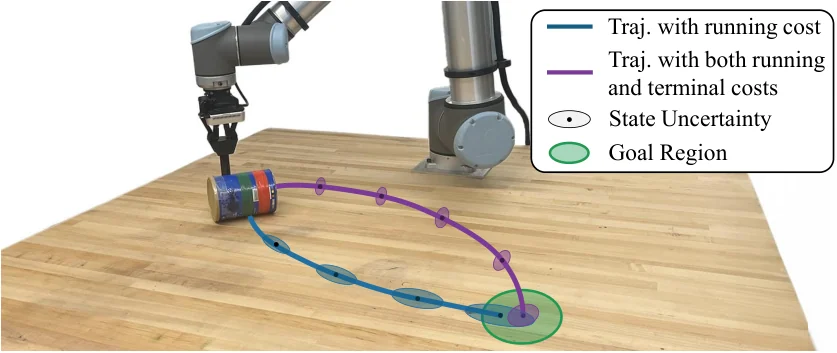
Terminal Matters (KiTe) examples of planar pushing and car parking
arXiv preprint2026Preprint · KiTe

Terminal Matters: Kinodynamic Planning with a Terminal Cost and Learned Uncertainty in Belief State-Cost Space

Zhuoyun Zhong, Seyedali Golestaneh, Constantinos Chamzas

Adds terminal-state objectives and learned uncertainty to kinodynamic planning, including belief-space goal preferences.

arXivCode
BibTeX
@article{zhong2026terminal,
  title={Terminal Matters: Kinodynamic Planning with a Terminal Cost and Learned Uncertainty in Belief State-Cost Space},
  author={Zhong, Zhuoyun and Golestaneh, Seyedali and Chamzas, Constantinos},
  journal={arXiv preprint arXiv:2605.09046},
  year={2026}
}
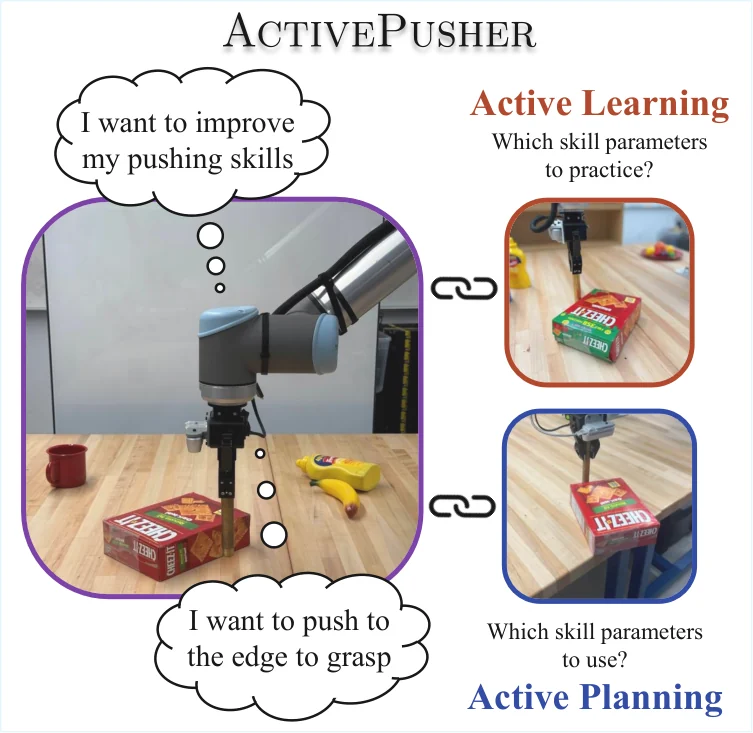
ActivePusher overview of active learning and planning for nonprehensile manipulation
IEEE International Conference on Robotics and Automation (ICRA)2026ICRA 2026 Best Student Paper Award

ActivePusher: Active Learning and Planning with Residual Physics for Nonprehensile Manipulation

Zhuoyun Zhong, Seyedali Golestaneh, Constantinos Chamzas

Nonprehensile skills such as pushing and rolling can support versatile manipulation, but learning their dynamics from scratch is costly and random interaction can waste trials. ActivePusher combines a residual-physics dynamics model with uncertainty-aware active learning to select informative skill parameters for data collection. It then connects the learned model to kinodynamic planners, using uncertainty to bias control sampling toward reliable actions over long-horizon plans. Simulation and real-robot experiments evaluate learning efficiency and manipulation performance; compared with the evaluated baselines, the method uses interaction data more effectively and achieves higher planning success.

arXivCodeVideo
BibTeX
@inproceedings{zhong2026activepusher,
  title={ActivePusher: Active Learning and Planning with Residual Physics for Nonprehensile Manipulation},
  author={Zhong, Zhuoyun and Golestaneh, Seyedali and Chamzas, Constantinos},
  booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},
  year={2026}
}
IEEE Access, vol. 13, pp. 49018–490292025Journal article

Robust and Efficient Phase Estimation in Legged Robots via Signal Imaging and Deep Neural Networks

Kamyab Yazdipaz, Nooshin Kohli, Seyed Ali Golestaneh, Mohammad Shahbazi

Uses signal-image representations and neural networks to estimate leg phase from proprioceptive measurements.

DOI
BibTeX
@article{yazdipaz2025phase,
  title={Robust and Efficient Phase Estimation in Legged Robots via Signal Imaging and Deep Neural Networks},
  author={Yazdipaz, Kamyab and Kohli, Nooshin and Golestaneh, Seyed Ali and Shahbazi, Mohammad},
  journal={IEEE Access},
  volume={13},
  pages={49018--49029},
  year={2025},
  doi={10.1109/ACCESS.2025.3549165}
}